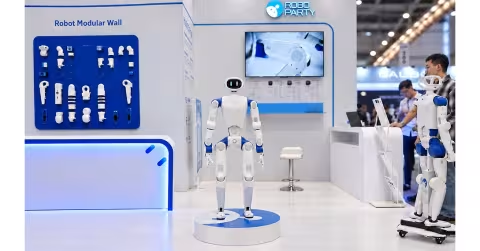
Pittsburgh – October 03, 2026 -- RoboParty unveiled RP1 (ROBOTO 01), a bipedal humanoid robot it calls the world's first high-performance full-stack open-source humanoid, at IROS 2026 on September 28. The robot delivers peak joint torque of up to 160 N·m, powered by in-house Romomo actuator modules and a real-time motion-control system.